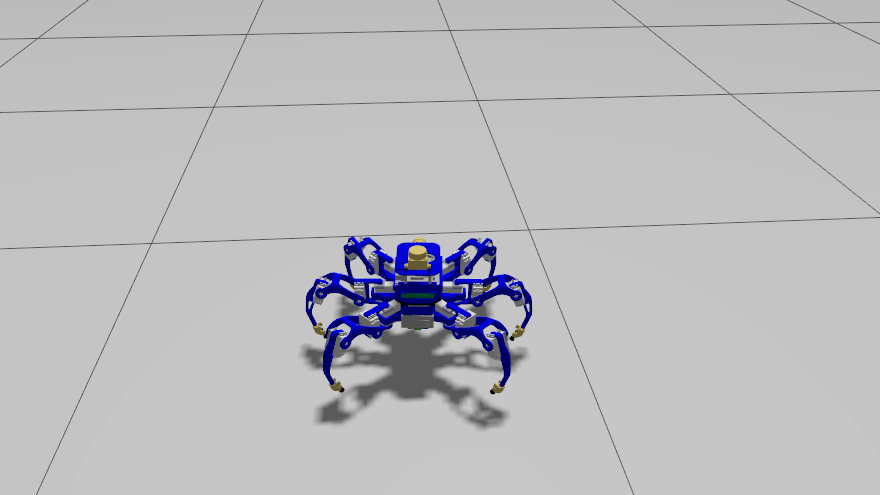
From Boxed-In to Open-Yoke: Redesigning the Hexapod Leg for the ST3020
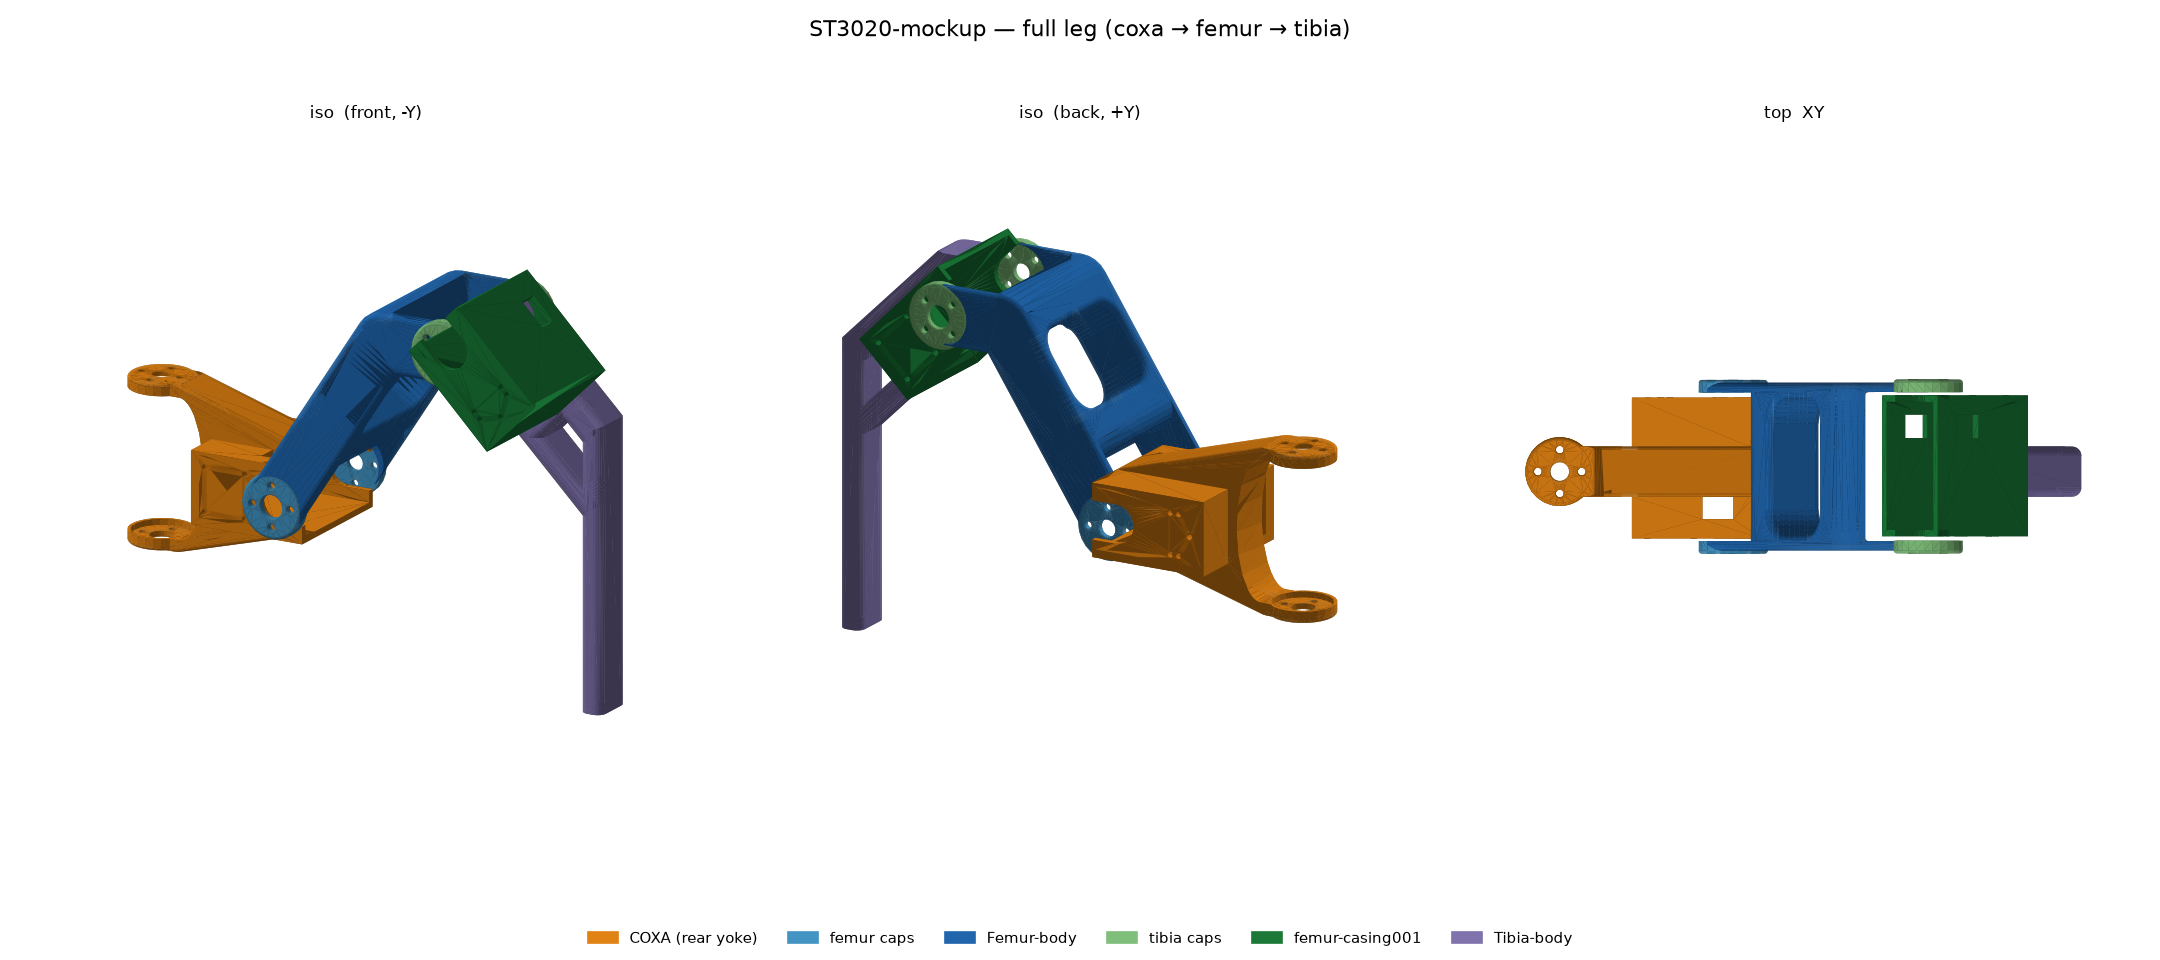
Three ST3020 serial-bus servos arrived a couple of weeks ago, and the plan was simple on paper: swap them in for the hexapod’s current DS3235 legs. It did not stay simple, but it landed somewhere better than where it started. Why change the servos at all The short version: a whole separate investigation (the gait-rework … Read more